Two arms.
One open platform.
R2D3 is Droid’s dual-arm mobile manipulation platform for robotics development, coordinated manipulation, and simulation-led experimentation.
BY DROID · REVIEWED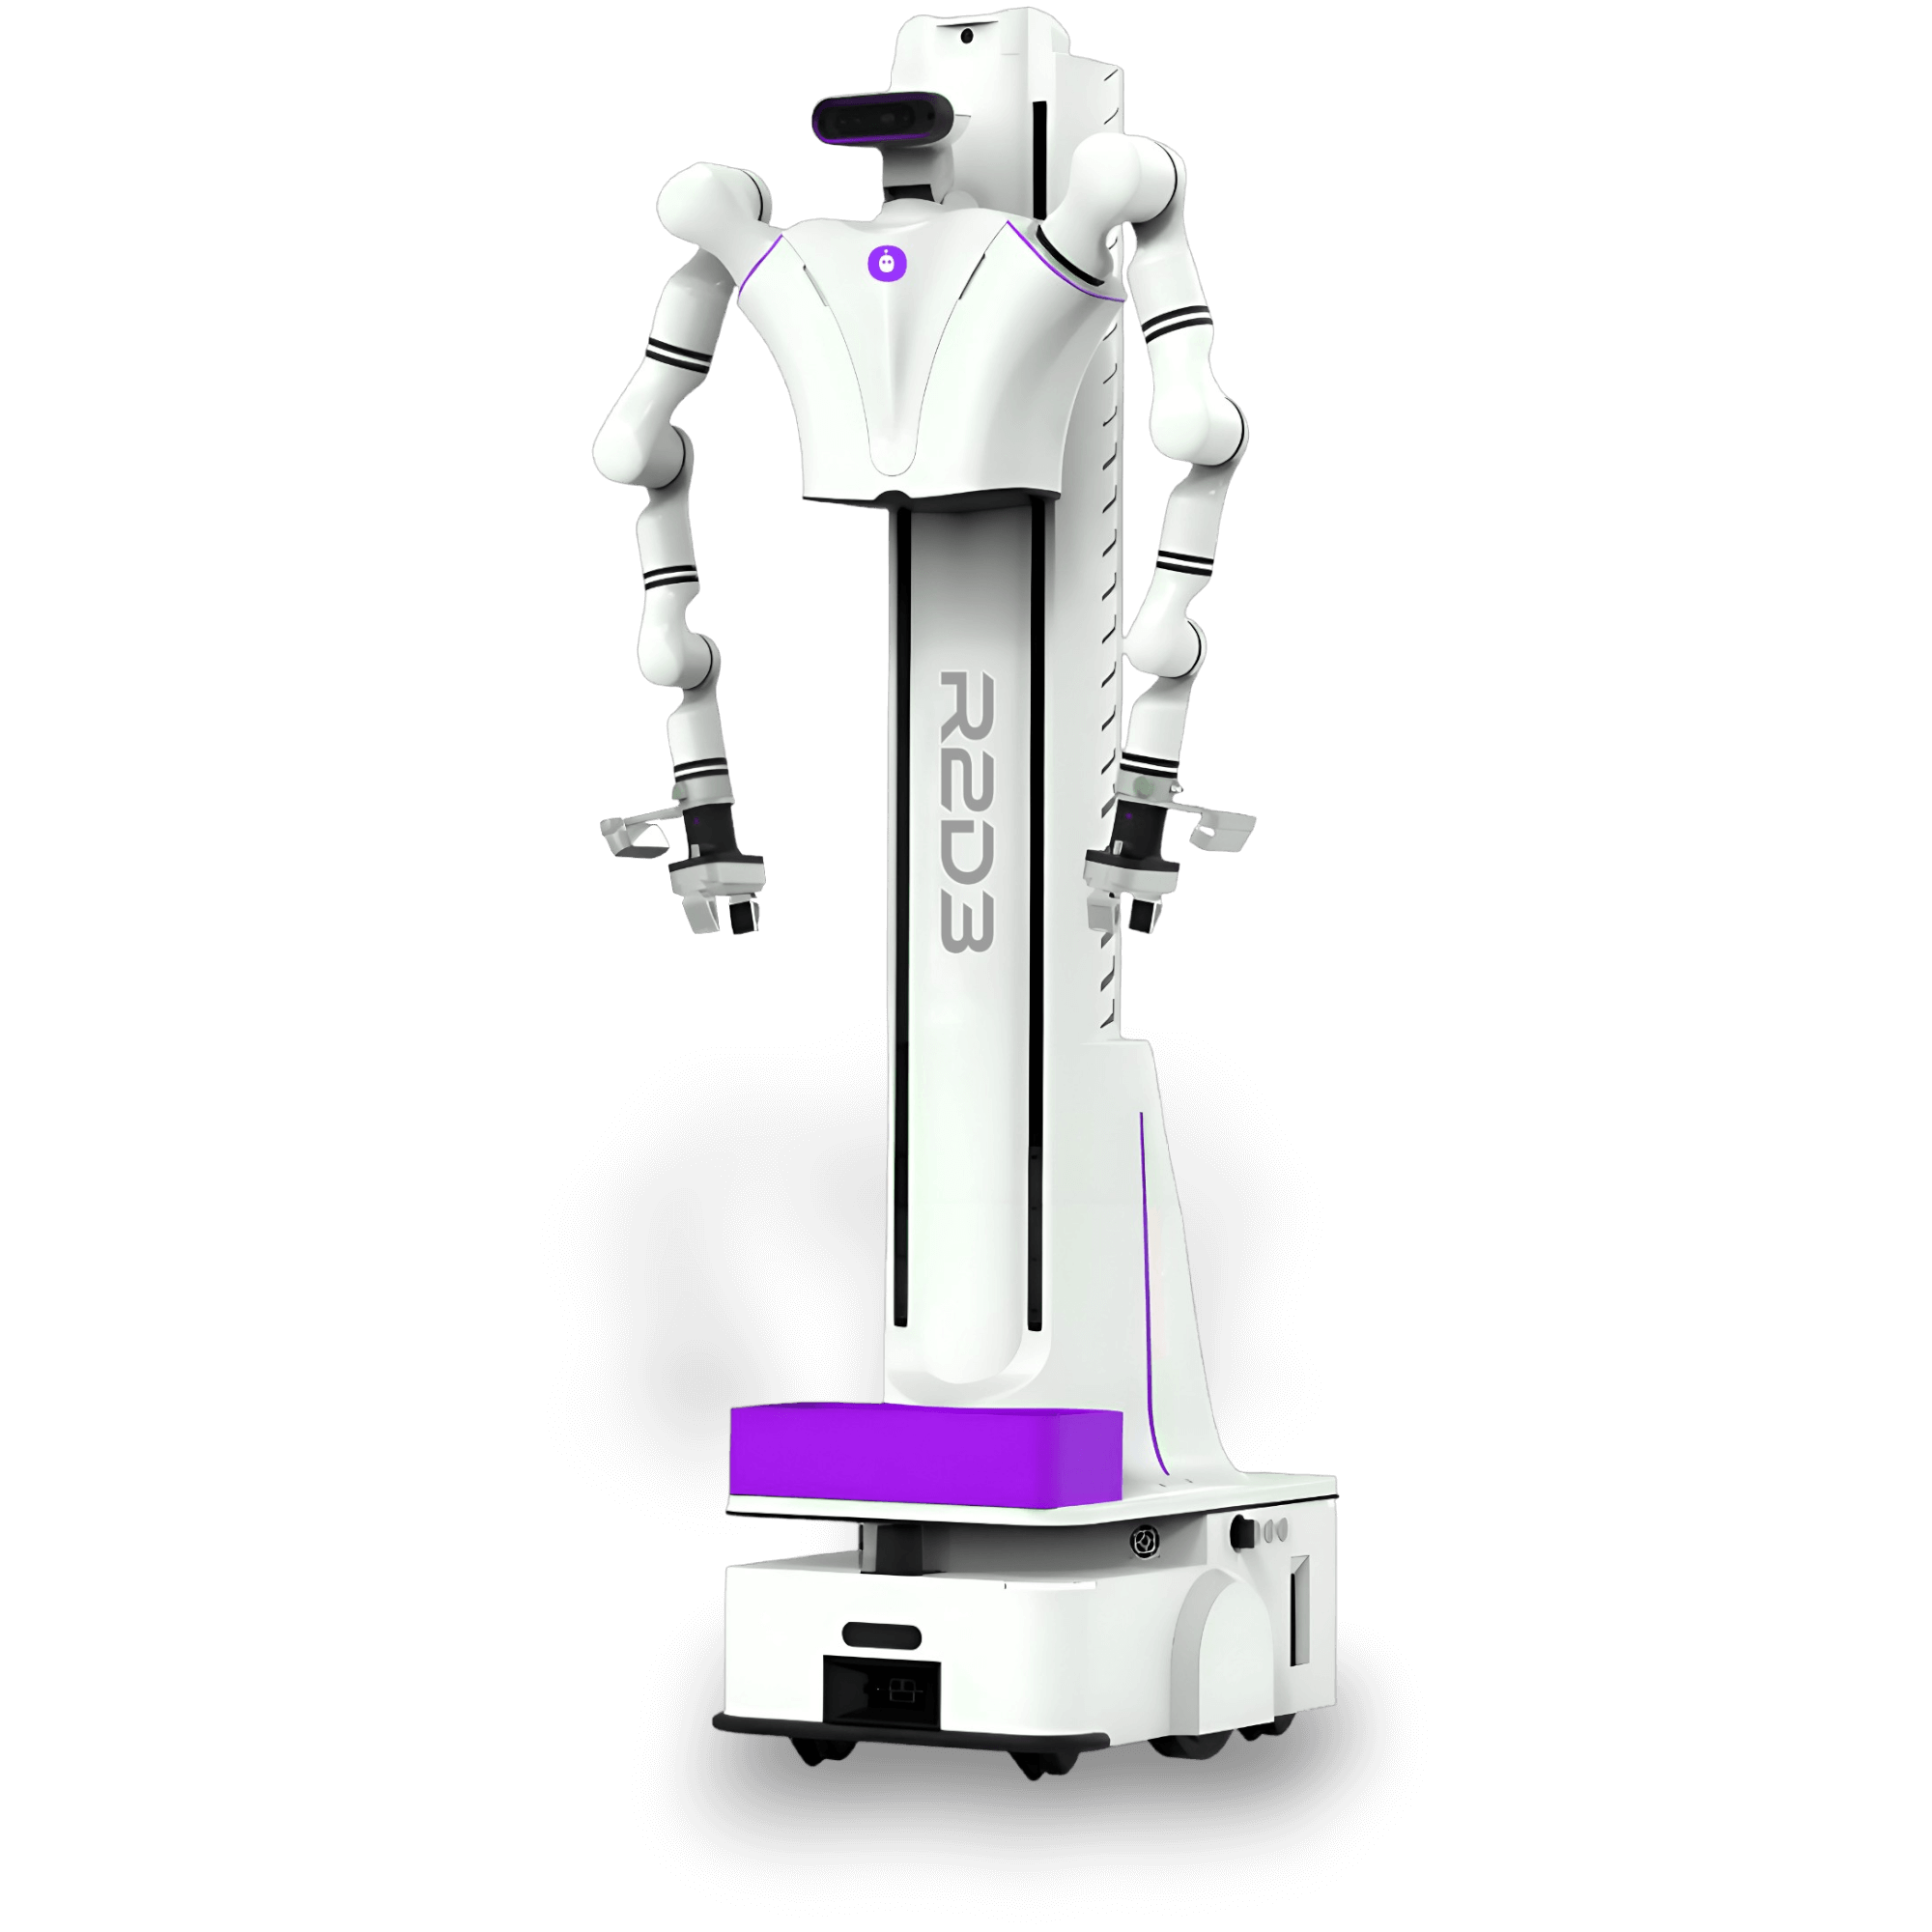
Develop the whole system.
Mobility, a lifting torso, two arms, and perception create a starting point for tasks that involve both reaching and moving. Begin with a specific object and workflow, then validate the complete behavior.
Who should evaluate it?
- Research teams exploring dual-arm mobile manipulation.
- Developers testing perception, navigation, and manipulation together.
- Integrators investigating a task-specific robotic system.
It is a development platform. Site readiness and task performance require their own evaluation.
Architecture you can inspect.
| System | Public documentation |
|---|---|
| Mobile base | The repository describes differential drive, a 2D lidar, and an IMU. |
| Lifting torso | A column raises and lowers the two arms. |
| Arm variants | RealMan RM65-B (6-DOF) or RM75-B (7-DOF), with a RealSense D435 wrist camera per arm. |
| Head sensing | A pan/tilt neck carries a ZED 2 stereo camera. |
| Software workspace | ROS 2 Jazzy, with navigation and manipulation packages documented in the public repository. |
| Simulation | Gazebo Harmonic or MuJoCo; the README describes shared robot descriptions, topics, frames, and controllers. |
Source: R2D3 public README at the reviewed revision. These are documented configurations, not a promise that every unit or quote includes every listed component. Payload, reach, speed, battery runtime, price, and lead time should be confirmed for the intended build.
Start in simulation.
The repository documents a container workflow for Gazebo and MuJoCo. Read its prerequisites and current instructions before running commands on your machine.
git clone https://github.com/Open-Droids-robot/R2D3_ros2.git
cd R2D3_ros2
./droid up             # Gazebo Harmonic
./droid up --mujoco    # MuJoCo alternative
Simulation helps develop and inspect behavior. Hardware bring-up, calibration, safety checks, and validation in the target environment remain separate work.
What to confirm
before a project.
- Exact arm, gripper, sensor, and compute configuration.
- Required payload, reach, objects, routes, and cycle times.
- Software and hardware licenses for the components you will use.
- Who integrates, calibrates, operates, and maintains the system.
- Written pilot criteria, intervention limits, and support scope.
R2D3 is part of Droid.
Droid was formerly known as Open Droids. The public repository retains that name. Meet the company and its other platforms, or read why we build in the open.
Bring us the task.
Let’s find the fit.
Share your environment, the job to be done, and the outcome you need to measure.