Droid.
Formerly Open Droids.
We develop robotics platforms and bring mechanical design, software, and integration together around real-world tasks.
BY DROID · REVIEWED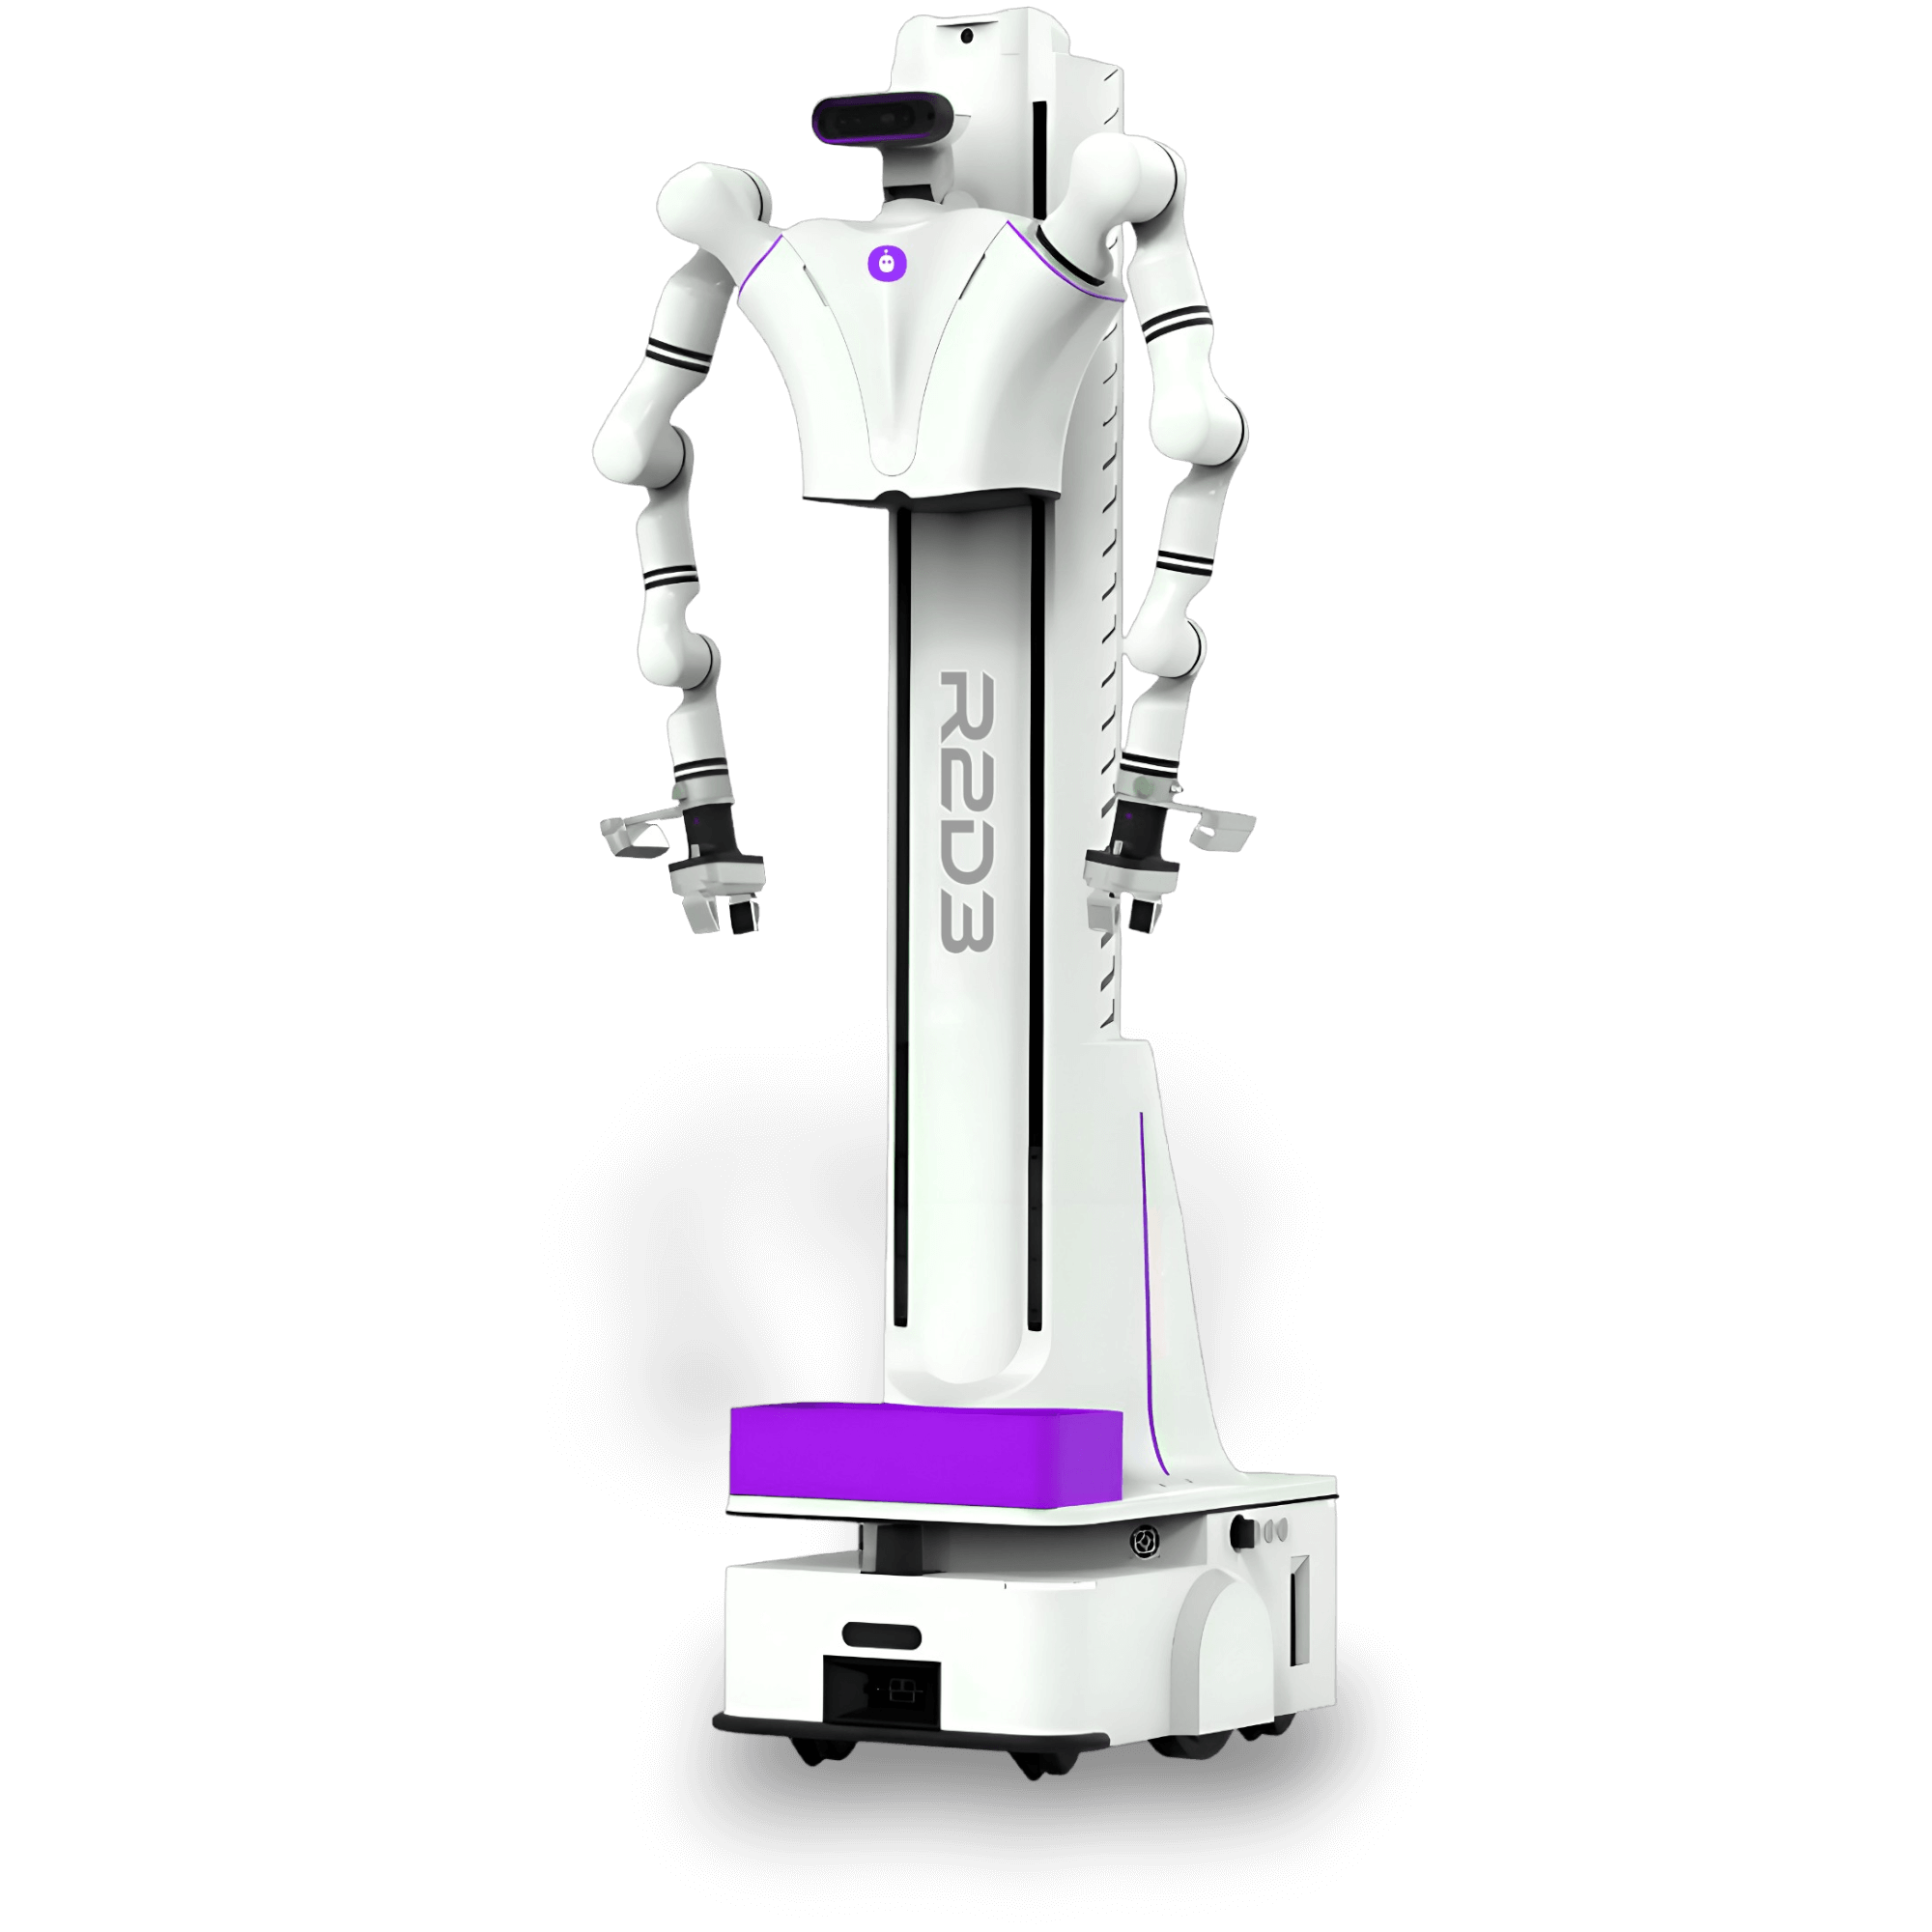
Open robotics.
A practical starting point.
Droid is the robotics company at droid.org, previously known as Open Droids and OpenDroids. Our platforms support work on mobile manipulation, coordinated arms, and embodied intelligence.
Researchers can start with public code and simulation. Operators can start with a task, a site, and a pilot that measures whether the system fits.
Find the right starting point.
| Platform | Starting point | Explore |
|---|---|---|
| R2D3 | Dual-arm mobile manipulation, public ROS 2 workspace, and simulation. | R2D3 platform |
| R1D3 | A mobile base, lift, and configurable single-arm platform. | R1D3 overview |
| R1D1 | Single-arm robotics development and public robot-description files. | R1D1 platform |
| DH116 & data glove | Dexterous hardware and motion-data tools. | Dexterous hand · Data glove |
Configuration, availability, pricing, support, and suitability depend on the project. A demonstration or simulation does not establish unattended performance in your environment.
Start with the public work.
Inspect the code and each repository’s license, dependencies, and current instructions before choosing a platform. Open software does not make every hardware component interchangeable.
A real project starts with a clear brief.
Describe the object, route, environment, and intervention you want to reduce. Establish site constraints and acceptance criteria before treating a product demo as a deployment plan.
The long-term vision.
The Abundance Protocol tells a proposed future of droids building droids and shared abundance. Its automated factories and cities are a vision, separate from the platform configurations and project work described here.
The robotics company is distinct from the unrelated DROID robotics dataset. The former droid.org capital-formation site is preserved at market.droid.org. Existing Open Droids GitHub and social handles remain useful links to the same robotics work.
Bring us the task.
Let’s find the fit.
Share your environment, the job to be done, and the outcome you need to measure.